Nikita Cheniuntai.
I design and ship industrial robotics, construction 3D printing, and AI for CNC - hardware that works in the field.
Apis Cor founder. NASA Habitat Challenge winner. Guinness Record holder. Now building AI for CNC manufacturing.

What I build
- 01Industrial robotics systems
- 02Construction-scale automation
- 03CNC + manufacturing systems
- 04AI-driven physical infrastructure
AI for CNC manufacturing.
Waymo moment for parts production.
- 01
AI alone doesn’t move the needle in manufacturing. Quoting automation is backwards because price is a result of the production strategy, not the starting point. The same CNC part can be made in many ways, with completely different cost and cycle time. Real automation has to start on the shop floor first, then extend into quoting and workflows.
- 02
We are building an AI-native CNC platform with humanoid-grade robotic intelligence, where machines can “see” and “feel” the cutting process through real-time sensor feedback.
- 03
Next-day CNC part production at dramatically lower cost is a national advantage. It would accelerate every major industry by bringing software-speed iteration to hardware manufacturing.
Projects
- 012026–PresentAI / Manufacturing
AI for CNC Manufacturing
Current focus - applying AI to CNC manufacturing to automate the most expensive parts of the machining workflow.
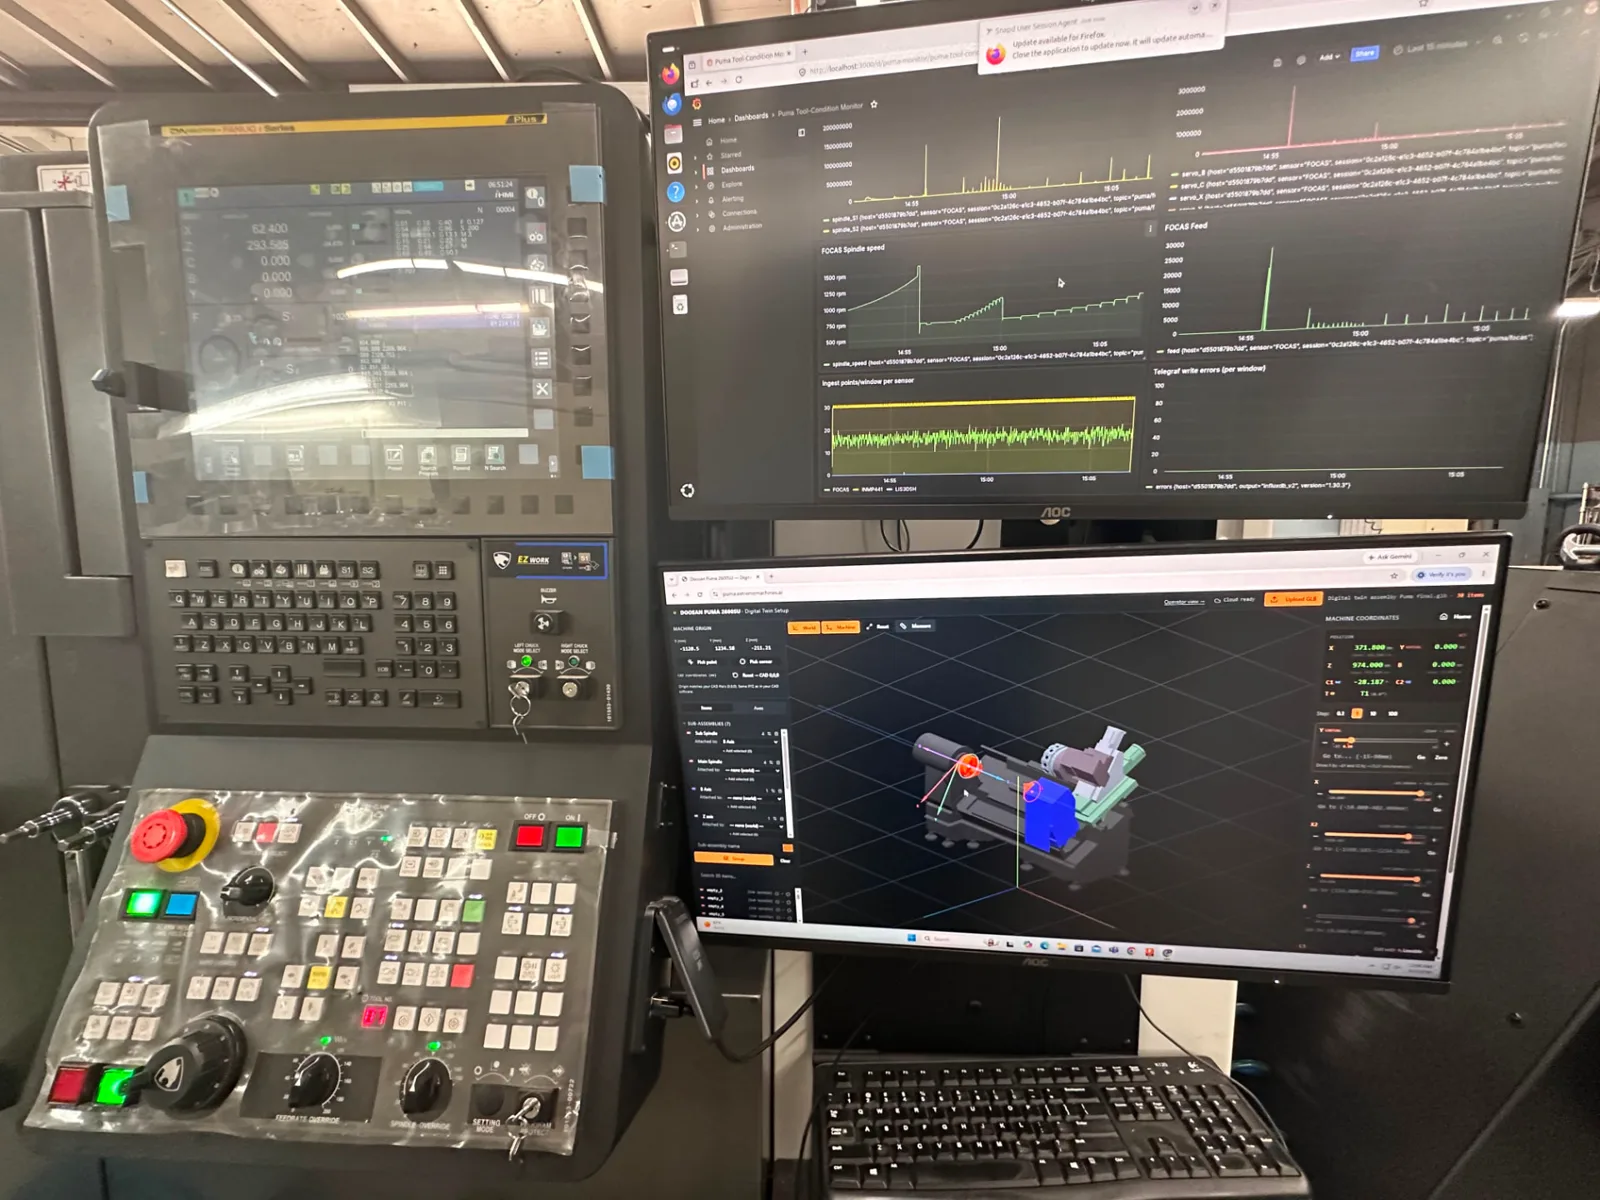 AI for CNC Manufacturing
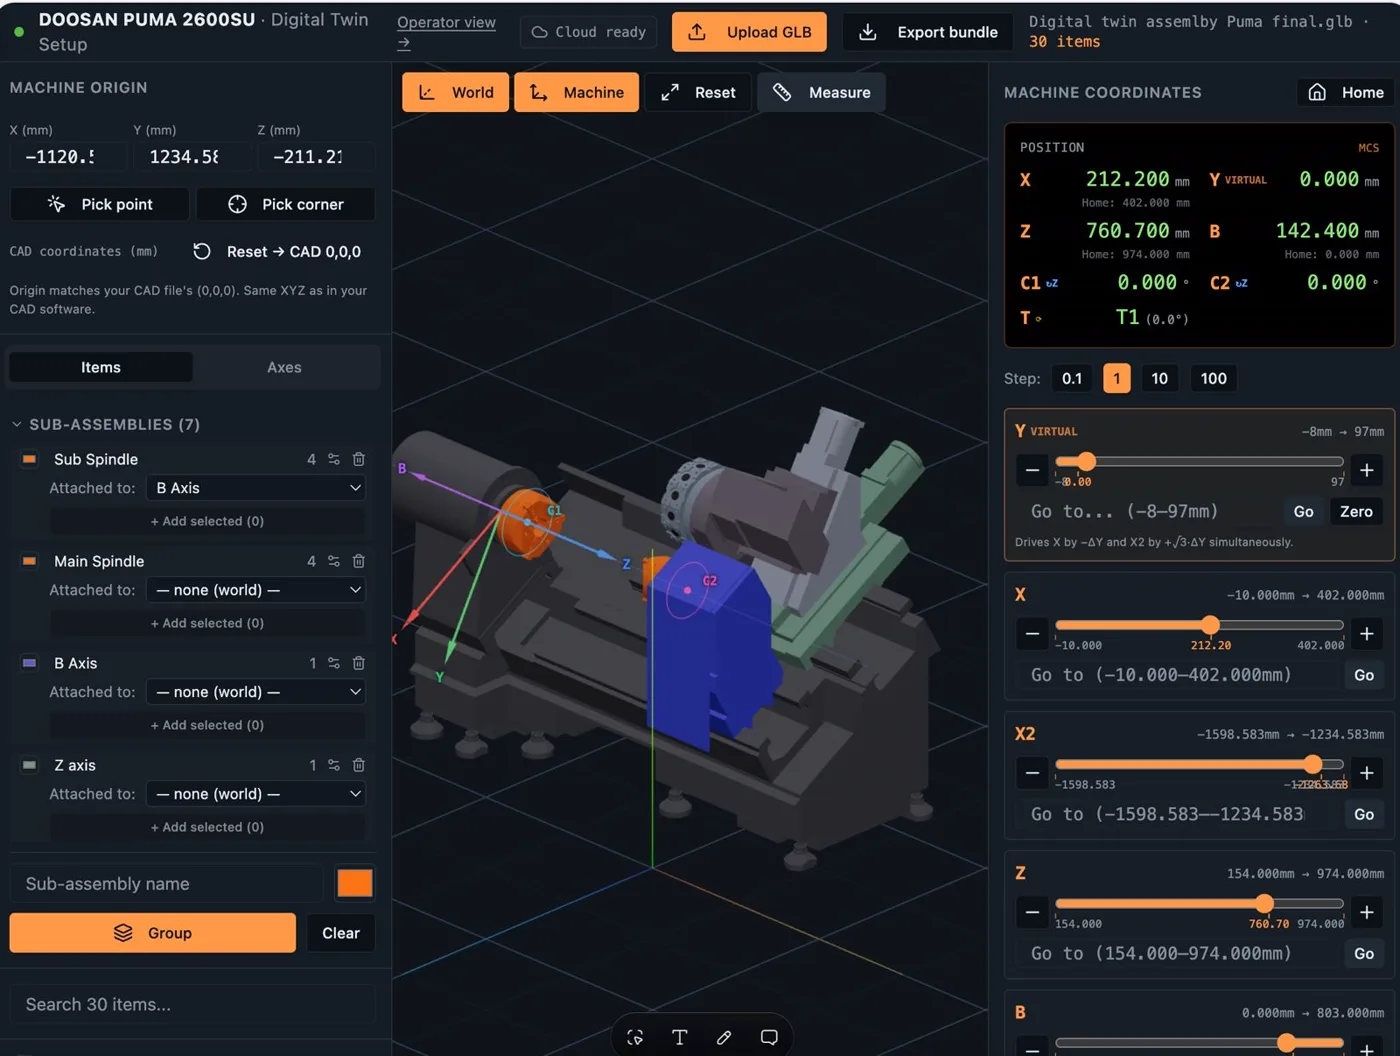 Detail
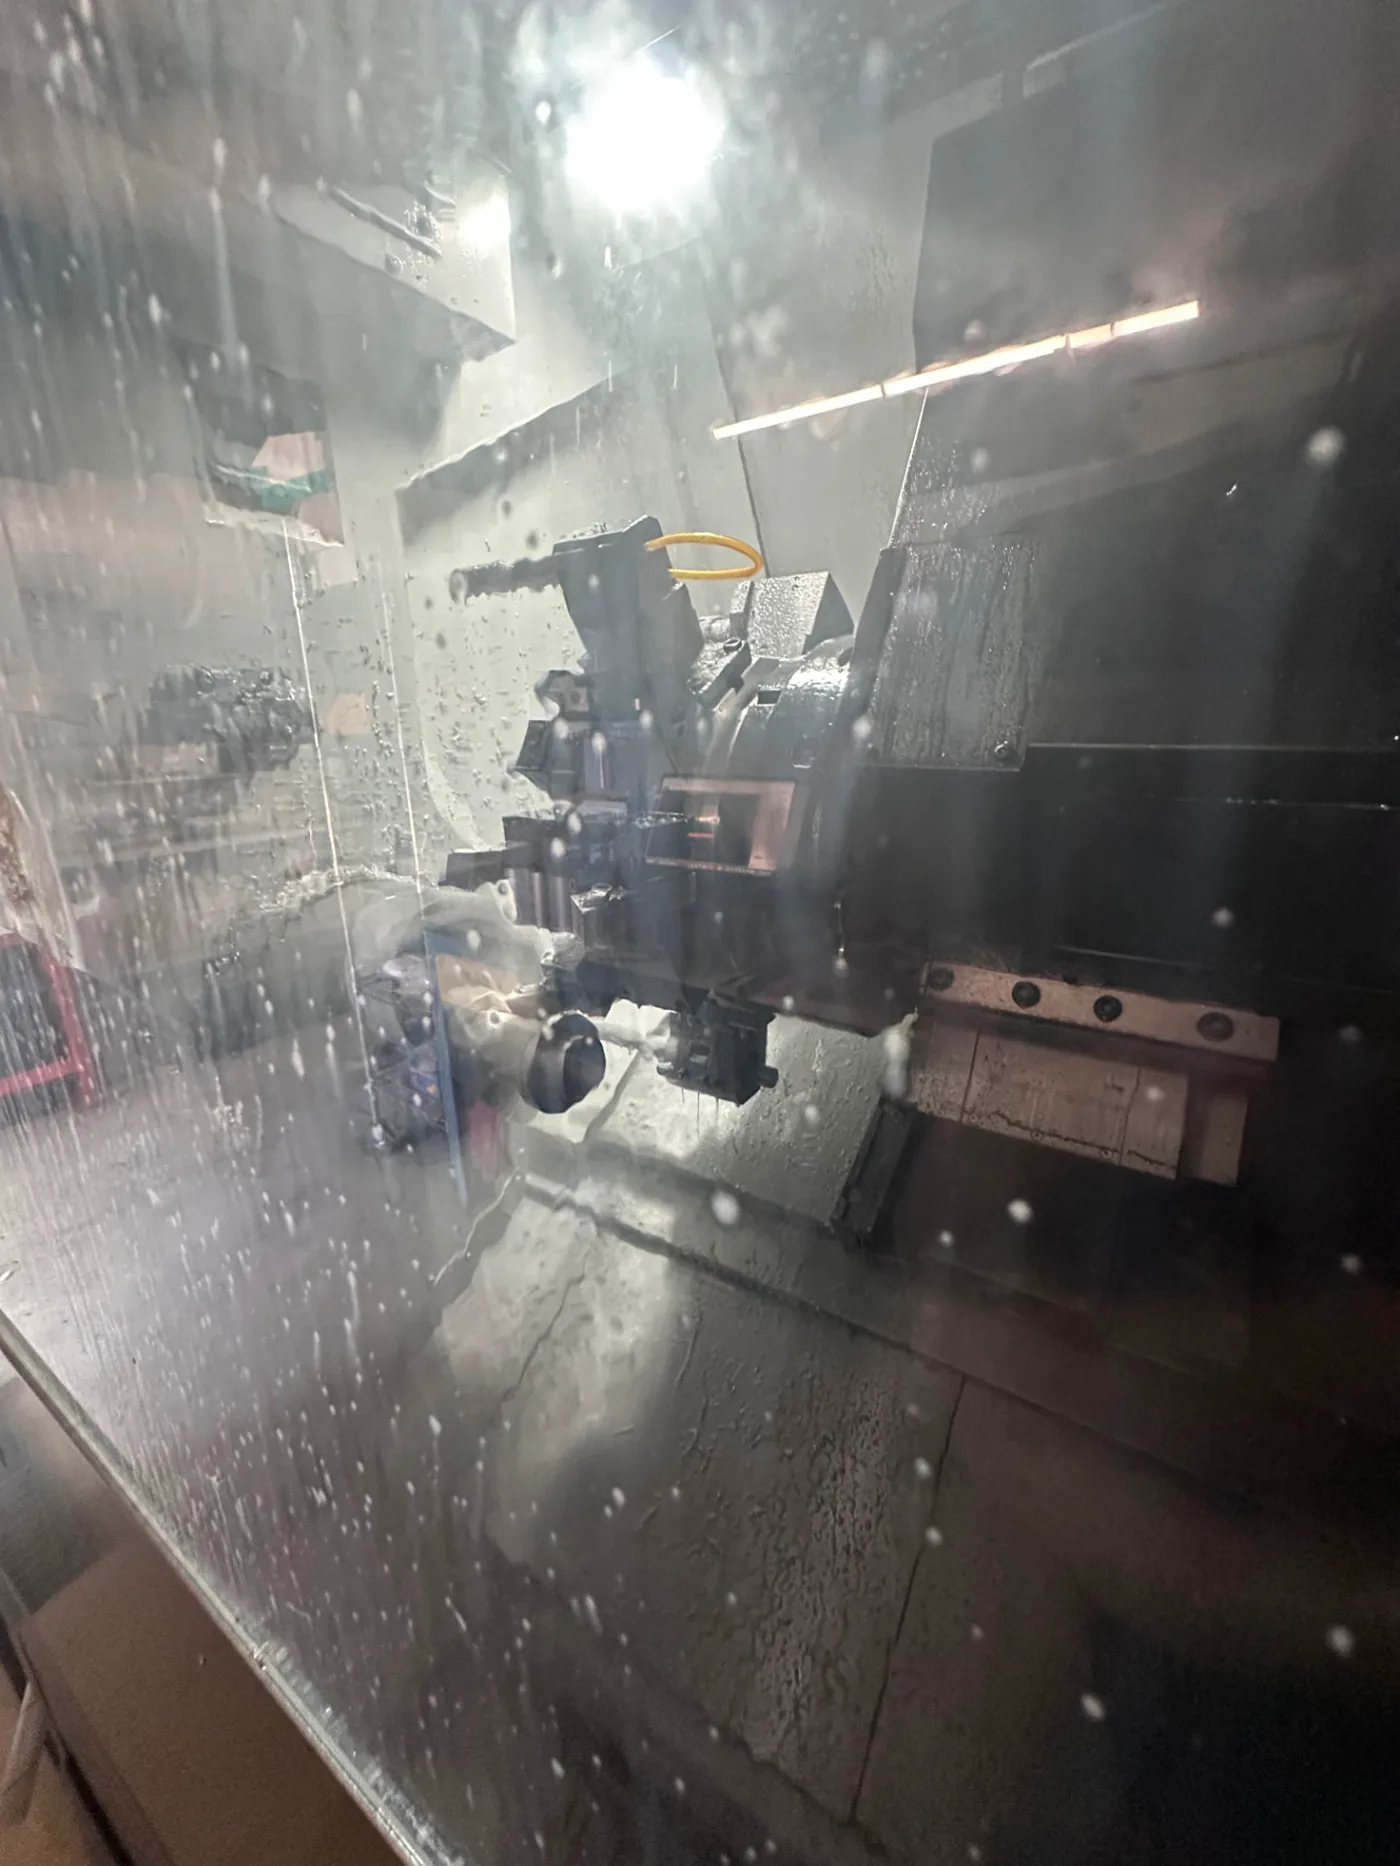 On-siteProblem
CNC manufacturing still depends on highly skilled operators for setup, programming, and inspection. It's slow, expensive, and doesn't scale.
ResultActive R&D. Early results show meaningful reductions in setup and programming time on real production work.
How it was builtBuilding an AI system that understands parts, machines, and process - collapsing the gap between a CAD file and a finished, inspected part.
- 022017–2026Construction Robotics
Apis Cor - Construction 3D Printing System
Built a full-scale, mobile robotic system that 3D prints buildings on-site.
 Apis Cor - Construction 3D Printing System
 Detail
 On-siteProblem
Construction is the least automated trillion-dollar industry. Existing 3D printing was lab-scale, not deployable in the field.
ResultDeployed in real-world environments. Used to print the world's largest 3D printed building in Dubai - Guinness World Record.
How it was builtDesigned a new type of construction machinery from scratch - the Apis Cor Printer and Mixer. A 14-axis robot with a custom-built motion controller, custom servomotors, and custom encoders.
- 032018Aerospace / Autonomy
NASA 3D Printed Habitat Challenge - Autodesk Build Space
Autonomous robotic construction for off-world habitats.
 NASA 3D Printed Habitat Challenge - Autodesk Build Space
 Detail
 On-siteProblem
NASA needed proof that lunar and Martian shelters could be built autonomously, with zero human intervention, from in-situ materials.
ResultWon the NASA 3D Printed Habitat Challenge against global engineering teams.
How it was builtDeveloped a fully autonomous robotic construction system capable of printing structural habitats end-to-end.
- 042019Industrial Deployment
Dubai - Biggest 3D Printed Building on the Planet
The largest 3D printed building ever constructed - industrial-scale robotic construction deployed in the field.
 Dubai - Biggest 3D Printed Building on the Planet
 Detail
 On-siteProblem
Translating lab robotics into a working construction site at extreme scale, in extreme heat, with real materials and real schedules.
ResultPrinted the Guinness World Record building in Dubai - one of the largest real-world validations of construction robotics to date.
How it was builtLed on-site deployment of the construction-scale 3D printing system end-to-end.
- 052020Field Deployment
Texas Boca Chica - 3D Printed House
Experimental construction deployment inside the Texas environment.
 Texas Boca Chica - 3D Printed House
 Detail
 On-siteProblem
Validate that construction robotics can operate in extreme, unstructured industrial environments alongside aerospace operations.
ResultDemonstrated construction robotics under extreme conditions adjacent to active aerospace operations.
How it was builtDeployed and 3D printed a prototype housing structure in Boca Chica, Texas.
- 06Early workCNC / Motion Control
Custom CNC Machinery
A series of custom CNC machines built from scratch - 5-axis plasma cutter, 3-axis vertical mill, and more.
 Custom CNC Machinery
 Detail
 On-siteProblem
Needed a high-degree-of-freedom fabrication tool with custom motion planning, and there was no off-the-shelf option.
ResultEarly foundation in industrial robotics and CNC - the basis for everything that came later.
How it was builtDesigned and built multiple CNC machines end-to-end - mechanics, motion control, and fabrication integration. Including a 5-axis plasma cutter and a custom 3-axis vertical mill.
- 07R&DIndustrial Process
Rivida Prototype - Wastewater Ammonia Recovery
Pro bono work helping my friend Andrea build the MVP for her company. My way of giving back.
 Rivida Prototype - Wastewater Ammonia Recovery
 Detail
 On-siteProblem
Farm wastewater dumps recoverable ammonia into the environment. Existing systems are too expensive or not field-deployable.
ResultFunctional experimental system for environmental processing - now an open R&D track.
How it was builtBuilt a prototype recovery system based on NASA patent research, adapted for agricultural environments.
Built from scratch.
Deployed in the field.
Over 10 years in industrial robotics. I designed a construction 3D printing system from scratch as a 14-axis robot with a custom motion controller - and took it from first sketch to Guinness World Record and first place in the NASA 3D Printed Habitat Challenge.
I work full-stack from mechanism to software: mechanics, motion control, firmware, and the AI layer. Systems built this way survive real job sites - they are not demos.
Now I am applying the same approach to AI for CNC manufacturing.
Execution philosophy
Physical, not just software
Build systems that move atoms - not only bits.
Prototype → deployment
Move fast from bench to real-world site.
Hardware-first thinking
Work directly with materials, machines, industry.
Real-world validation
Sites and customers over simulations and decks.